
Engineering Project Videos
See FUYA's wall-climbing robots in action across real-world engineering projects.
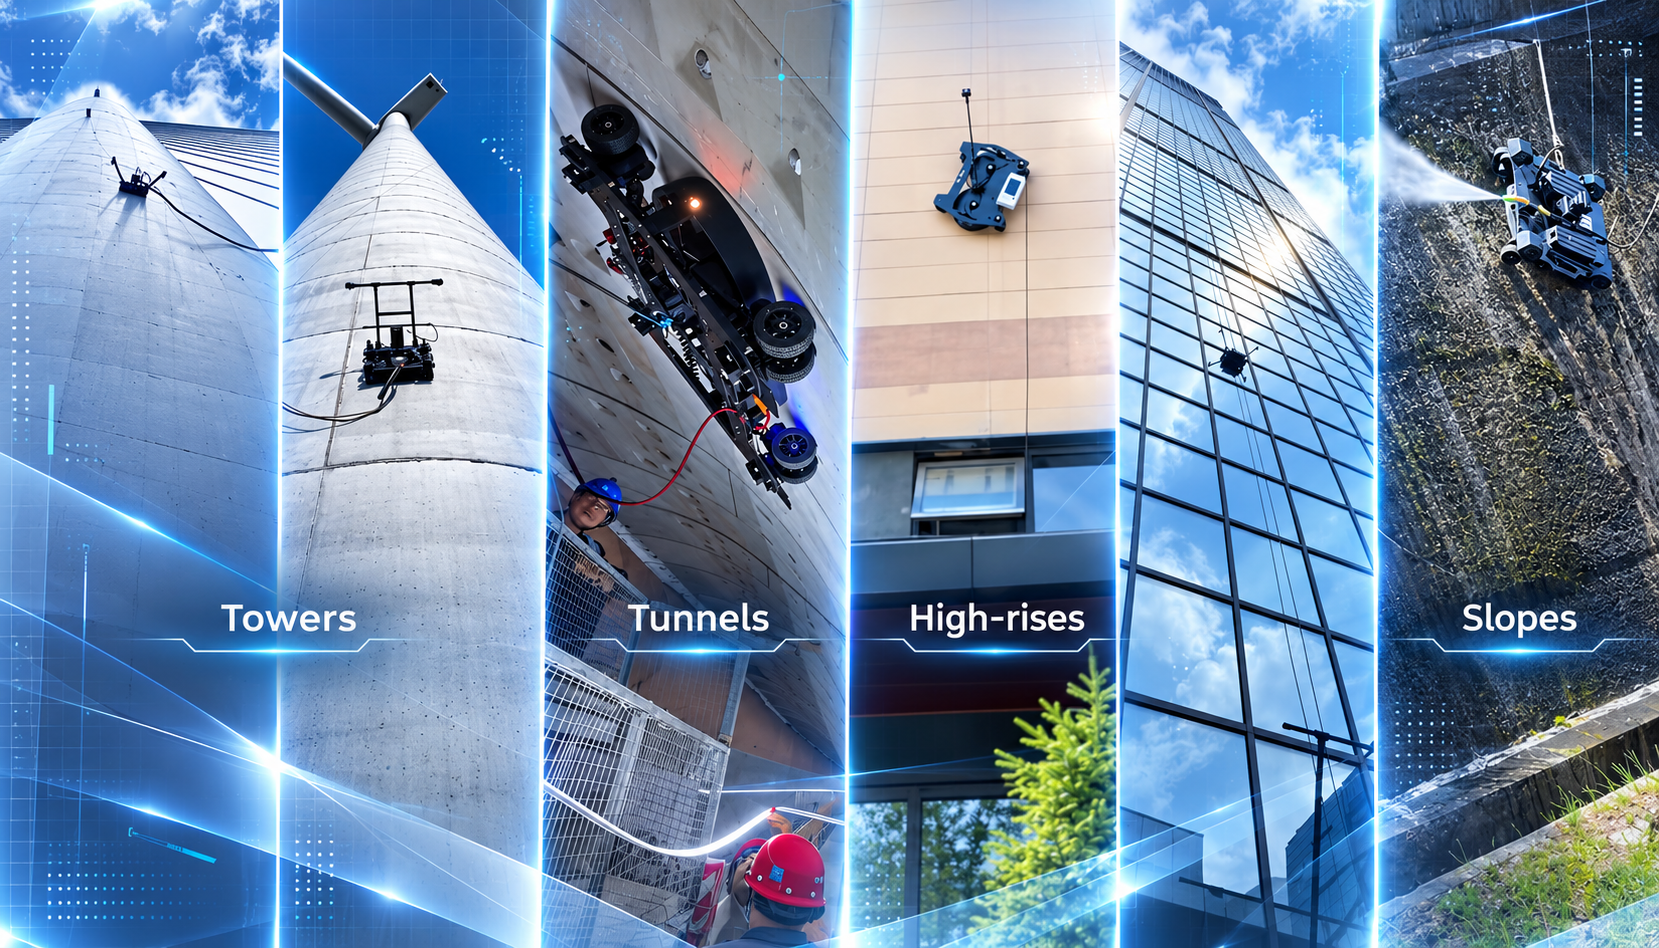
Engineering Applications of Wall-Climbing Robots
General introduction to wall-climbing robot products and their engineering applications.
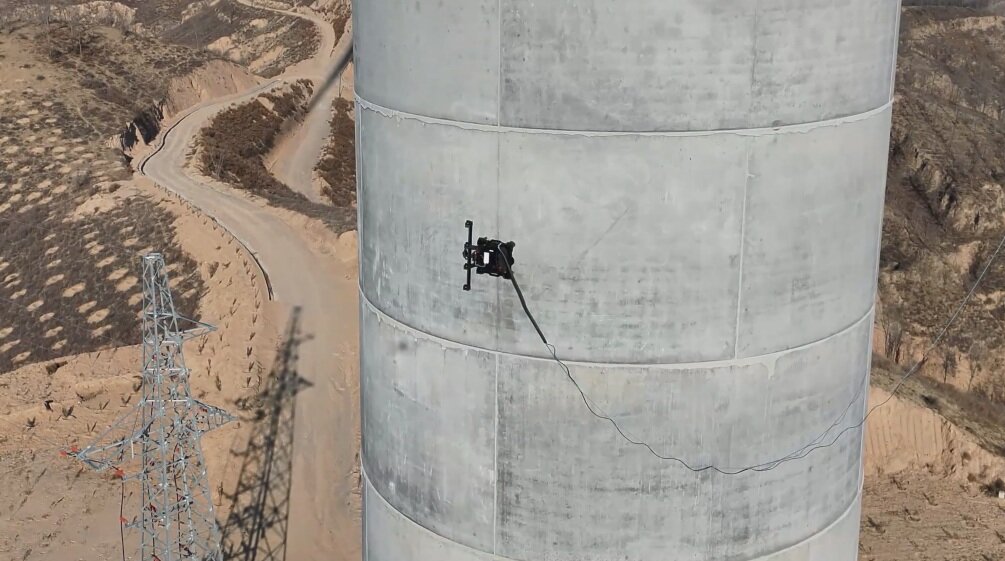
Wind Turbine Blade and Tower Inspection
The wall-climbing robot can be equipped with multiple high-definition cameras and dual ultrasonic probes to inspect wind turbine towers and blades for surface and internal defects.
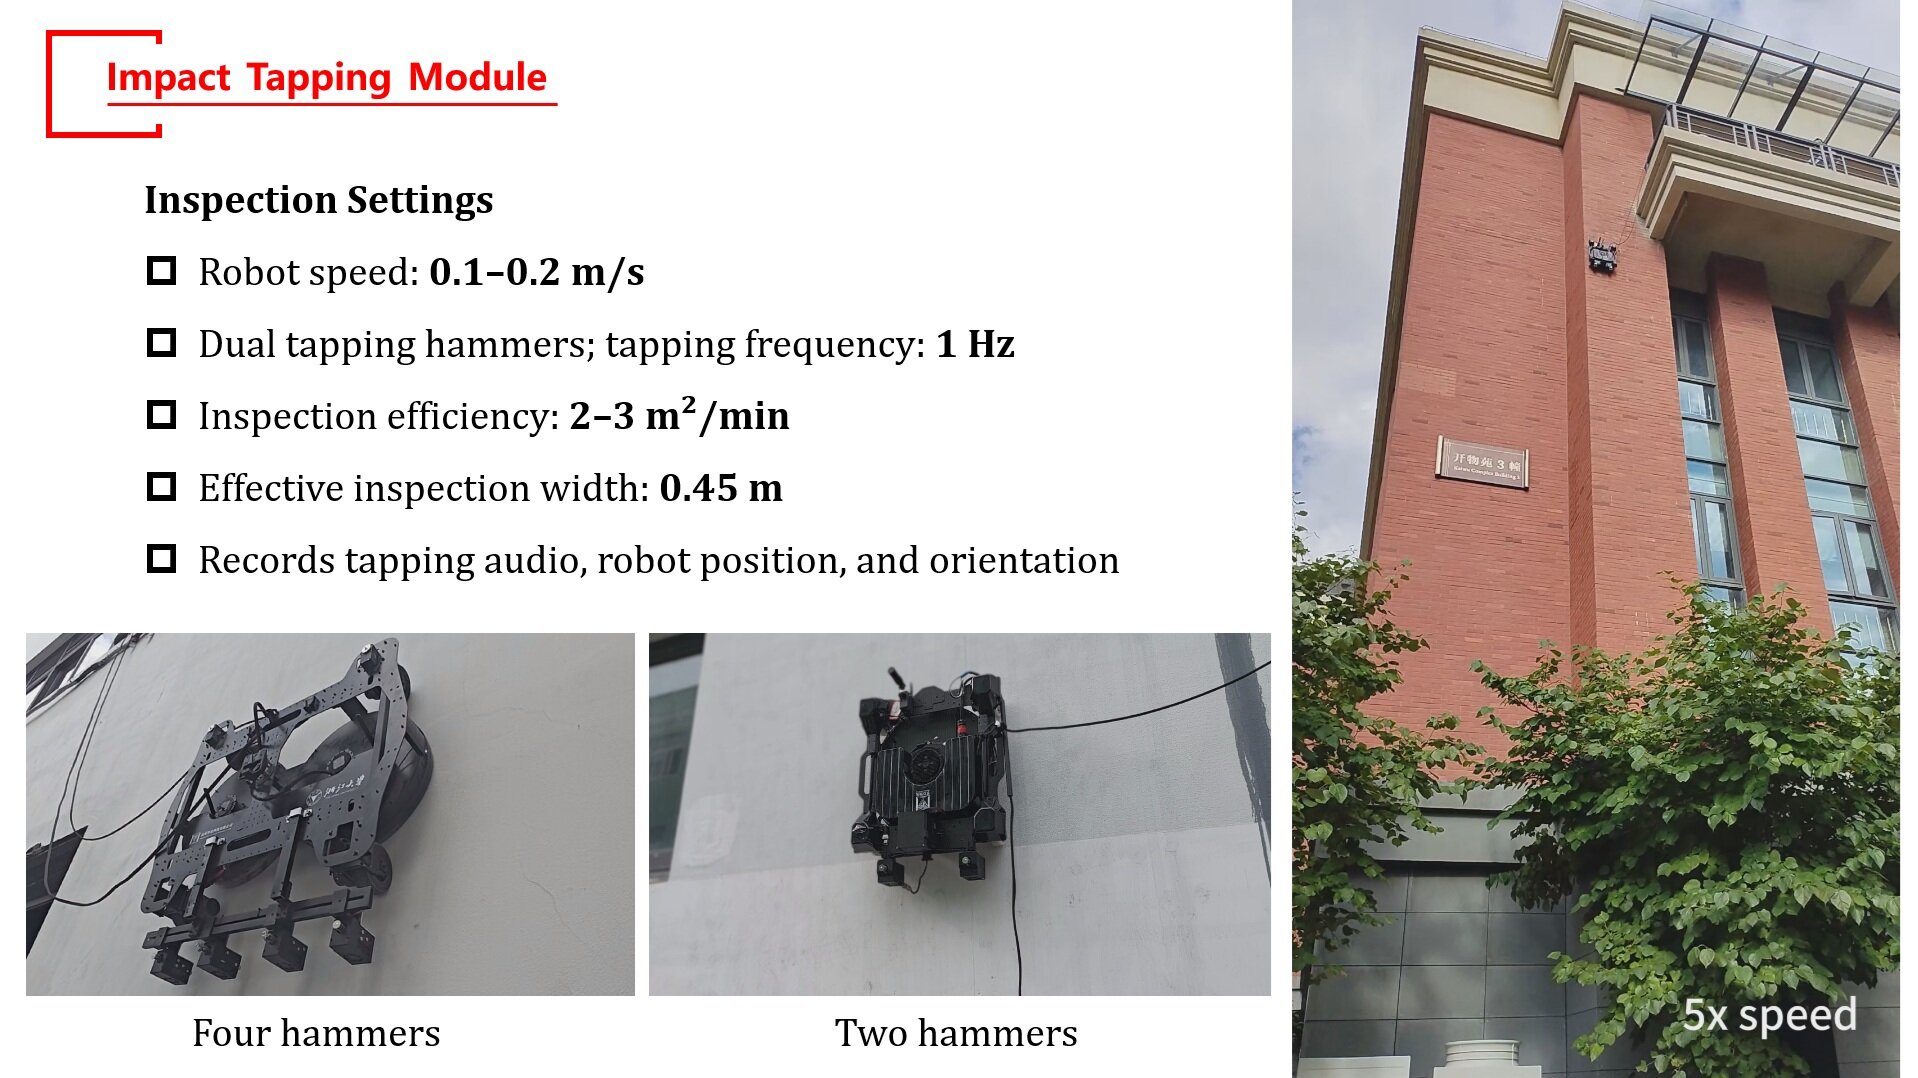
Hammer Tapping Module
A hammer tapping module has been developed for wall inspection. The module has two- and four-hammer versions. The robot moves at 0.1–0.2 m/s, and each hammer taps at 1 Hz while recording audio with position and orientation. Using about 60–100 human-labeled samples, thresholds are set to detect hollow areas. The results are marked on a wall map.

Bridge Tower Inspection and Maintenance at Shenzhen Bay Bridge, Hong Kong
In 2025, FUYA collaborated with Hong Kong Highways Department to complete the bridge tower inspection and maintenance project of Shenzhen Bay Bridge.

Glass Curtain Wall Sealant Inspection of Inland Revenue Building, Hong Kong
In 2025, FUYA collaborated with Hong Kong Architectural Services Department to complete the partial glass curtain wall sealant inspection project of the Inland Revenue Building.

Pole Climbing Robot and Robotic Arm System for Pole Rust Removal and Painting
Developed the pole climbing robot and robotic arm system for rust removal and painting maintenance of light poles on cross-sea bridges.